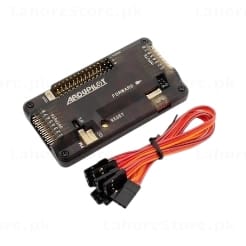
APM 2.8 ArduPilot Flight Controller with Built-in Compass - ArduCopter Multirotor Autopilot Board
APM 2.8 ArduPilot Flight Controller with Built-in Compass - ArduCopter Multirotor Autopilot Board
Regular price
Rs.22,500
Regular price
Sale price
Rs.22,500
Shipping calculated at checkout.
Quantity
Couldn't load pickup availability
APM 2.8 ArduPilot Flight Controller - ArduCopter / ArduPlane Autopilot Board with Built-in Compass
The APM 2.8 is a mature and proven open-source autopilot board based on the ArduPilot project. Used widely in DIY drones, multirotors, fixed-wing aircraft, and ground rovers, the APM 2.8 features a built-in barometer, 3-axis gyroscope, accelerometer, and compass - giving you a full IMU + navigation sensor suite in one compact board. Comes with servo PWM connector cables included.

Key Features
- APM 2.8 autopilot board - latest revision of the popular open-source ArduPilot platform
- Built-in HMC5883L compass - no external compass module required
- MS5611 barometric pressure sensor - accurate altitude hold and altitude readings
- MPU-6000 IMU - 3-axis gyroscope and 3-axis accelerometer on a single chip
- ATmega2560 processor - 256KB flash, runs full ArduCopter / ArduPlane / ArduRover firmware
- USB port for firmware upload and mission planner connection
- Servo / PWM output rail - up to 8 channels for ESC and servo control
- UART ports for GPS, telemetry radio, and OSD connection
- I2C and SPI expansion headers
- PWM servo cable set included

Specifications
- Model: APM 2.8
- Processor: ATmega2560 (256KB flash)
- IMU: MPU-6000 (3-axis gyro + 3-axis accelerometer)
- Barometer: MS5611
- Compass: HMC5883L (built-in)
- Firmware: ArduCopter, ArduPlane, ArduRover (open-source)
- Input Voltage: 5V (via USB or power module)
- PWM Outputs: 8 channels
- Interfaces: USB, UART x3, I2C, SPI, ADC
- GPS Port: UART with 5V power output
- Dimensions: 70 x 45 x 15mm (approx.)

Compatible With
- ArduCopter firmware - quadcopter, hexacopter, octocopter, Y6, X8 configurations
- ArduPlane firmware - fixed-wing aircraft and flying wings
- ArduRover firmware - ground vehicles and boats
- Mission Planner GCS (Windows) and APM Planner 2 (cross-platform)
- u-blox NEO-6M / NEO-7M / NEO-8M GPS modules
- 3DR / SiK telemetry radios (433MHz / 915MHz)
- MinimOSD and other MAVLink-compatible OSD modules
Perfect For
- DIY Quadcopter and Multirotor Build Projects
- Fixed-Wing UAV and FPV Plane Autopilot
- ArduPilot Learning and Drone Development
- University Aerospace and Robotics Projects
- Autonomous Ground Vehicle and Rover Control
- Drone Racing and Long-Range FPV with Autopilot Assist
Order now and build your own ArduPilot-powered autonomous drone or UAV with the proven APM 2.8 flight controller.